
Satellite GNC Demo
Download this exampleSatelliteGNC.zipFull project — Dyad model + Julia + data
A CubeSat-class spacecraft flies a rest-to-rest three-axis repointing maneuver — roll 20°, pitch 10°, yaw 30° simultaneously — tracking a trapezoidal slew profile on each axis.
To arrive on target without overshooting, the controller has to know how fast the craft is already turning, and the one sensor aboard reports only which way it is pointing. A Luenberger observer supplies the missing turn rate: it runs a small model of the spacecraft alongside the real one and nudges that model into agreement with each new star-tracker angle.
The loop ships twice. The 3-DOF version uses ideal torque actuation. The 6-DOF version flies a 400 km orbit, where the same controller acts through eight discrete thrusters and a pseudoinverse allocator.
The model
TestFullGNC is the assembled 3-DOF loop: three slew profiles, the PD-with- feedforward attitude controller, the observer closing the rate loop, and the rigid-body plant:
Running it
Run the 40 s maneuver and plot the attitude response:
using SatelliteGNC, Plots

result = TestFullGNCSim()
plot(result)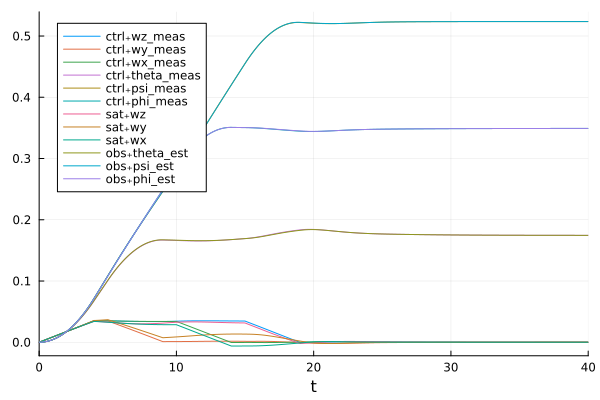
The thruster-actuated orbital variant is TestFullGNC6DOFSim(), built on TestFullGNC6DOF. See the demo's notes.md for the architecture and pole placement, and docs/algorithm_description.md for the per-component specifications.