PID Autotuning Analysis
Download as a Dyad projectPIDAnalysis.zipOpen in Dyad Studio
The PID autotuning analysis is used to automatically tune the parameters of a PID controller for a given model. The analysis computes optimal PID gains that satisfy frequency-domain robustness constraints, such as maximum sensitivity (Ms), complementary sensitivity (Mt), peak noise sensitivity (Mks), and integrated noise sensitivity (Mks2).
Method Overview
PID autotuning in DyadControlSystems is based on step-response optimization, subject to robustness constraints on closed-loop sensitivity functions. The method performs joint optimization of a PID controller and a measurement filter on either of the forms
by solving
subject to
where abs2). The user can select which signals to optimize, the reference value, and the filter order.
The transfer functions in the frequency-domain constraints are defined as follows:
Sensitivity:
Complementary sensitivity:
Noise sensitivity:
See control-system sensitivity and DyadControlSystems autotuning documentation for more information.
Example Definition
The following example will demonstrate autotuning of a PID controller for an active suspension system. The model of the system is available in DyadExampleComponents.
Since the PID autotuning analysis internally opens the loop at the measurement point y, the connection from seat_pos.s to pid.u_m is broken during linearization, and pid.u_m becomes a free input that needs an operating-point value. We also need to pin the algebraic spring-damper forces and the internal PID-block outputs so that the linearization solver does not encounter cyclic guesses. We use Dyad's guess keyword to provide these operating-point values:
using DyadExampleComponents, DyadInterface
ActiveSuspensionPIDAutotuningAnalysis() # hide
solution = ActiveSuspensionPIDAutotuningAnalysis()
┌ Warning: The initialization system is structurally singular. Guess values may significantly affect the initial values of the ODE. The problematic variables are SymbolicUtils.BasicSymbolicImpl.var"typeof(BasicSymbolicImpl)"{SymReal}[car_and_suspension₊mass₊s(t), car_and_suspension₊spring_damper₊s_rel0, seat₊spring_damper₊s_rel0].
│
│ Note that the identification of problematic variables is a best-effort heuristic.
└ @ ModelingToolkitBase ~/.julia/packages/ModelingToolkitBase/N5KVH/src/problems/initializationproblem.jl:140
┌ Warning: Initialization system is underdetermined. 0 equations for 11 unknowns. Initialization will default to using least squares. `SCCNonlinearProblem` can only be used for initialization of fully determined systems and hence will not be used here.
│
│
│ Call `analyze_initialization_jacobian(prob)` on the constructed problem to see which unknowns are underdetermined (and which equations, if any, are redundant).
│
│ To suppress this warning, pass `warn_initialize_determined = false`. To turn this warning into an error, pass `fully_determined = true`.
└ @ ModelingToolkit ~/.julia/packages/ModelingToolkit/ZgEKM/src/initialization.jl:25
******************************************************************************
This program contains Ipopt, a library for large-scale nonlinear optimization.
Ipopt is released as open source code under the Eclipse Public License (EPL).
For more information visit https://github.com/coin-or/Ipopt
******************************************************************************
This is Ipopt version 3.14.19, running with linear solver MUMPS 5.9.0.
Number of nonzeros in equality constraint Jacobian...: 0
Number of nonzeros in inequality constraint Jacobian.: 2404
Number of nonzeros in Lagrangian Hessian.............: 0
Total number of variables............................: 4
variables with only lower bounds: 4
variables with lower and upper bounds: 0
variables with only upper bounds: 0
Total number of equality constraints.................: 0
Total number of inequality constraints...............: 601
inequality constraints with only lower bounds: 0
inequality constraints with lower and upper bounds: 0
inequality constraints with only upper bounds: 601
iter objective inf_pr inf_du lg(mu) ||d|| lg(rg) alpha_du alpha_pr ls
0 1.1089185e-02 1.45e+01 1.14e-01 0.0 0.00e+00 - 0.00e+00 0.00e+00 0
5 1.0522811e-02 1.29e+01 2.27e-01 -5.4 6.70e+01 - 6.31e-03 3.31e-03h 1
10 7.4366640e-03 2.28e+03 2.13e+01 -0.7 1.78e+03 - 2.15e-02 1.27e-02f 1
15 7.1678939e-03 0.00e+00 1.20e+02 0.2 3.77e+02 - 2.38e-02 2.44e-01f 1
20 9.2469686e-03 0.00e+00 5.67e+01 -0.0 5.18e+01 - 8.86e-01 1.00e+00h 1
25 5.7540576e-03 0.00e+00 7.86e-03 -4.2 1.60e+01 - 9.92e-01 1.00e+00h 1
30 4.1134438e-03 0.00e+00 1.22e-02 -4.5 5.94e+01 - 1.00e+00 1.00e+00h 1
35 1.0104852e-03 0.00e+00 5.79e-04 -5.4 2.74e+01 - 9.99e-01 1.00e+00h 1
40 6.0712668e-04 0.00e+00 7.54e-04 -6.7 2.39e+00 - 6.91e-01 1.00e+00h 1
Number of Iterations....: 42
(scaled) (unscaled)
Objective...............: 6.0118943309683435e-04 6.0118943309683435e-04
Dual infeasibility......: 2.0811264791115461e-07 2.0811264791115461e-07
Constraint violation....: 0.0000000000000000e+00 0.0000000000000000e+00
Variable bound violation: 0.0000000000000000e+00 0.0000000000000000e+00
Complementarity.........: 1.1377472139212053e-08 1.1377472139212053e-08
Overall NLP error.......: 2.0811264791115461e-07 2.0811264791115461e-07
Number of objective function evaluations = 43
Number of objective gradient evaluations = 43
Number of equality constraint evaluations = 0
Number of inequality constraint evaluations = 44
Number of equality constraint Jacobian evaluations = 0
Number of inequality constraint Jacobian evaluations = 43
Number of Lagrangian Hessian evaluations = 0
Total seconds in IPOPT = 103.203
EXIT: Optimal Solution Found.
┌ Warning: The initialization system is structurally singular. Guess values may significantly affect the initial values of the ODE. The problematic variables are SymbolicUtils.BasicSymbolicImpl.var"typeof(BasicSymbolicImpl)"{SymReal}[car_and_suspension₊mass₊s(t), car_and_suspension₊spring_damper₊s_rel0, seat₊spring_damper₊s_rel0].
│
│ Note that the identification of problematic variables is a best-effort heuristic.
└ @ ModelingToolkitBase ~/.julia/packages/ModelingToolkitBase/N5KVH/src/problems/initializationproblem.jl:140
┌ Warning: Initialization system is underdetermined. 0 equations for 11 unknowns. Initialization will default to using least squares. `SCCNonlinearProblem` can only be used for initialization of fully determined systems and hence will not be used here.
│
│
│ Call `analyze_initialization_jacobian(prob)` on the constructed problem to see which unknowns are underdetermined (and which equations, if any, are redundant).
│
│ To suppress this warning, pass `warn_initialize_determined = false`. To turn this warning into an error, pass `fully_determined = true`.
└ @ ModelingToolkit ~/.julia/packages/ModelingToolkit/ZgEKM/src/initialization.jl:25
This is Ipopt version 3.14.19, running with linear solver MUMPS 5.9.0.
Number of nonzeros in equality constraint Jacobian...: 0
Number of nonzeros in inequality constraint Jacobian.: 2404
Number of nonzeros in Lagrangian Hessian.............: 0
Total number of variables............................: 4
variables with only lower bounds: 4
variables with lower and upper bounds: 0
variables with only upper bounds: 0
Total number of equality constraints.................: 0
Total number of inequality constraints...............: 601
inequality constraints with only lower bounds: 0
inequality constraints with lower and upper bounds: 0
inequality constraints with only upper bounds: 601
iter objective inf_pr inf_du lg(mu) ||d|| lg(rg) alpha_du alpha_pr ls
0 1.1089185e-02 1.45e+01 1.14e-01 0.0 0.00e+00 - 0.00e+00 0.00e+00 0
5 1.0522811e-02 1.29e+01 2.27e-01 -5.4 6.70e+01 - 6.31e-03 3.31e-03h 1
10 7.4366640e-03 2.28e+03 2.13e+01 -0.7 1.78e+03 - 2.15e-02 1.27e-02f 1
15 7.1678939e-03 0.00e+00 1.20e+02 0.2 3.77e+02 - 2.38e-02 2.44e-01f 1
20 9.2469686e-03 0.00e+00 5.67e+01 -0.0 5.18e+01 - 8.86e-01 1.00e+00h 1
25 5.7540576e-03 0.00e+00 7.86e-03 -4.2 1.60e+01 - 9.92e-01 1.00e+00h 1
30 4.1134438e-03 0.00e+00 1.22e-02 -4.5 5.94e+01 - 1.00e+00 1.00e+00h 1
35 1.0104852e-03 0.00e+00 5.79e-04 -5.4 2.74e+01 - 9.99e-01 1.00e+00h 1
40 6.0712668e-04 0.00e+00 7.54e-04 -6.7 2.39e+00 - 6.91e-01 1.00e+00h 1
Number of Iterations....: 42
(scaled) (unscaled)
Objective...............: 6.0118943309683435e-04 6.0118943309683435e-04
Dual infeasibility......: 2.0811264791115461e-07 2.0811264791115461e-07
Constraint violation....: 0.0000000000000000e+00 0.0000000000000000e+00
Variable bound violation: 0.0000000000000000e+00 0.0000000000000000e+00
Complementarity.........: 1.1377472139212053e-08 1.1377472139212053e-08
Overall NLP error.......: 2.0811264791115461e-07 2.0811264791115461e-07
Number of objective function evaluations = 43
Number of objective gradient evaluations = 43
Number of equality constraint evaluations = 0
Number of inequality constraint evaluations = 44
Number of equality constraint Jacobian evaluations = 0
Number of inequality constraint Jacobian evaluations = 43
Number of Lagrangian Hessian evaluations = 0
Total seconds in IPOPT = 1.485
EXIT: Optimal Solution Found.using Plots
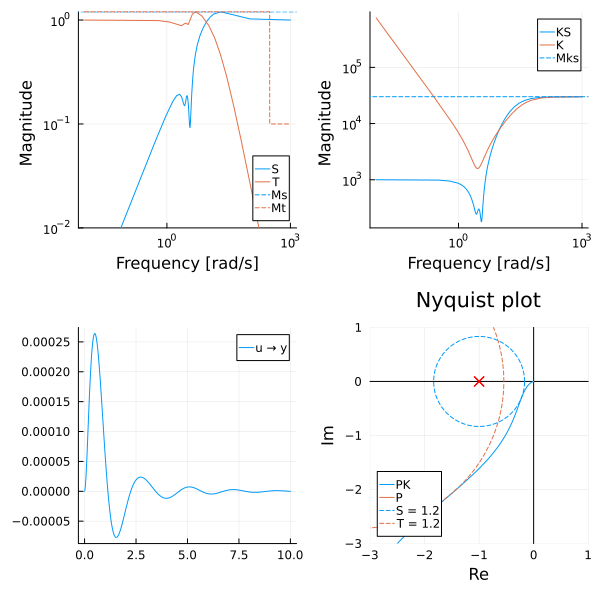
figs = artifacts(solution, :SensitivityFunctions)
fign = artifacts(solution, :NoiseSensitivityAndController)
figr = artifacts(solution, :OptimizedResponse)
figny = artifacts(solution, :NyquistPlot)
plot!(figs, ylims=(1e-2, Inf))
plot!(figny, legend=:bottomleft)
plot(figs, fign, figr, figny,
link = :none,
size = (600, 600),
)
We may also ask for the optimized controller parameters:
artifacts(solution, :OptimizedParameters)| Row | kp_parallel | ki_parallel | kd_parallel | Kp_standard | Ti_standard | Td_standard | Tf | Nd |
|---|---|---|---|---|---|---|---|---|
| Float64 | Float64 | Float64 | Float64 | Float64 | Float64 | Float64 | Float64 | |
| 1 | 1358.06 | 7573.58 | 854.719 | 1358.06 | 0.179316 | 0.629365 | 0.0298335 | 21.0959 |
Using the Tuned Controller in a Dyad Model
Use apply to load the tuned parameters from the :ControllerParameters TOML artifact:
print(artifacts(solution, :ControllerParameters))# PID controller parameters tuned by PIDAutotuningAnalysis.
# Place this file in the directory `assets` of a Dyad package `MyPackage` and load it with `apply`, e.g.,
# controller = BlockComponents.Continuous.LimPID(apply "dyad://MyPackage/pid.toml")
# Structural parameters set explicitly in the modification take precedence over `with_I` and `with_D` in this file.
with_I = true
with_D = true
k = 1358.0646941911252
Ti = 0.17931613230860868
Td = 0.6293654099068342
Nd = 21.095924191625503To save the parameters, add output_file = "pid.toml" to the extends DyadControlSystems.PIDAutotuningAnalysis(...) argument list in your analysis definition. Running the analysis writes pid.toml to the working directory. Move it to assets/pid.toml in MyPackage, then load it:
controller = BlockComponents.Continuous.LimPID(apply "dyad://MyPackage/pid.toml")The file's header comments identify the required controller structure:
| Analysis settings | Model structure |
|---|---|
Continuous, filter_order = 1 (default) | LimPID realizes the tuned controller exactly. |
Continuous, filter_order = 2 | Add BlockComponents.Continuous.SecondOrder low-pass filters named filter_y and filter_r for the measurement and reference. Apply the file to their parent component, which must also contain a LimPID named pid. The file has a table for each subcomponent. |
discrete_time = true | Use DiscreteComponents.DiscretePIDStandard with sample interval Ts. |
Tuning Several Controllers
PID autotuning handles one controller in one feedback loop. For broader tuning problems, use DyadControlSystems' StructuredAutoTuningProblem from Julia. It supports:
Multiple controllers, including cascade loops and interacting PIDs.
Other controller structures.
Multiple operating points or uncertain parameters.
It tunes arbitrary model parameters against time- and frequency-domain objectives at analysis points. It is not available as a Dyad analysis.
Export the result with parameter_file(res, path). The TOML file uses model-relative parameter names, with one table per subcomponent:
[inner_controller]
k = 2.1
Ti = 0.12

[outer_controller]
k = 8.5
Apply it to the component used to create the tuned model:
model = MyModel(apply "dyad://MyPackage/parameters.toml")Analysis Arguments
The following arguments define a PID autotuning analysis:
Required Arguments
model: The system model to be controlled.measurement::String: Name of the measured output signal.control_input::String: Name of the control input signal.step_input::String: Name of the step input signal.step_output::String: Name of the step output signal.Ts::Real: Discretization sampling time; also the controller sample interval whendiscrete_time = true.duration::Real: Simulation duration.Ms::Real: Maximum sensitivity constraint. Values between 1 and 2 are typical. A lower value increases robustness but may reduce performance.Mt::Real: Maximum complementary sensitivity constraint. Values between 1 and 2 are typical. A lower value increases robustness but may reduce performance.Mks::Real: Maximum noise sensitivity constraint. This controls the maximum amplification of measurement noise in the control signal.
Optional Arguments
ref::Real = 0.0: Reference value for the step input.Mks2::Real = 1e300: Upper bound on the H2 norm of the transfer function from measurement noise to the control signal. The default disables this constraint. It can be used independently ofMksor together with it.exact_h2::Bool = false: Whether to evaluate theMks2constraint using a Lyapunov equation over the full frequency range for continuous-time tuning. Withfalse, the analysis integrates over the frequency grid. See Integrated noise sensitivity.disc::String = "tustin": Discretization method.kp_lb,ki_lb,kd_lb,Tf_lb: Lower bounds for PID parameters.kp_ub,ki_ub,kd_ub,Tf_ub: Upper bounds for PID parameters.kp_guess,ki_guess,kd_guess,Tf_guess: Initial guesses for PID parameters.timeweight::Bool = false: Whether or not to use time-weighted optimization.filter_order::Int = 1: Noise filter order (1 or 2). 1 filters only the derivative term; 2 filters the measurement and reference, acting on the entire PID controller.optimize_d::Bool = false: Whether or not to optimize the damping parameter of the second-order filter.discrete_time::Bool = false: Tune aDiscreteComponents.DiscretePIDStandardwith sample intervalTsand default discretization methods. Requiresfilter_order = 1.output_file::String = "": Path for the tuned controller TOML file. Empty disables writing.wl::Real: Lower frequency bound for design.wu::Real: Upper frequency bound for design.num_frequencies::Int: Number of frequency points.soft::Bool: Whether or not to use soft constraints (may be beneficial for difficult problems).soft_penalty::Float64: The penalty factor for violating soft constraints. Defaults to1e6.exact_hessian::Bool = false: Whether or not to compute the exact Hessian using AD. This may improve performance in some cases, in particular if the solver requires many steps to converge. If exact Hessian is turned off, a Hessian-free algorithm will be used (IPOPT BFGS approximation).
Controller Structure
The optimized controller has the form:
for filter_order = 2, where filter_order = 1, only the derivative term is filtered, as shown in Method Overview.
Constraints
Sensitivity (
Ms): Limits the peak of the sensitivity function. Typical values are between 1 and 2. Complementary Sensitivity (
Mt): Limits the peak of. Typical values are between 1 and 2. Noise Sensitivity (
Mks): Limits the peak of, which determines the amplification of measurement noise in the control signal. Integrated Noise Sensitivity (
Mks2): Limits the H2 norm of, which accounts for the amplification of measurement noise across frequencies.
Lower values increase robustness but may reduce performance.
The peak
For example, a maximum sensitivity of
Integrated noise sensitivity
The peak constraint Mks permits a nearly constant noise gain above the filter cutoff frequency. The H2 constraint Mks2 limits the integral of the squared gain, so a controller with high noise gain over a broad frequency interval requires a larger bound. For a stable continuous-time closed loop,
For unit-intensity white measurement noise, this norm determines the standard deviation of the control signal. Mks and Mks2 have different units and numerical values; their bounds are selected independently.
With exact_h2 = false, the analysis applies the trapezoidal rule on the grid determined by wl, wu, and num_frequencies. It integrates with respect to angular frequency, including when the grid is logarithmic. Frequencies outside this interval are excluded. Use a sufficiently broad and dense grid and check the result after increasing the frequency range and resolution. For a first-order derivative filter, a finite integration interval represents a finite measurement-noise bandwidth.
With exact_h2 = true, the analysis evaluates the full-band norm using a Lyapunov equation. This method supports continuous-time tuning and requires filter_order = 2 and a strictly positive Tf_lb. A first-order derivative filter generally leaves a nonzero direct feedthrough from measurement noise to the control signal, which gives an infinite continuous-time H2 norm. A second-order filter acts on the entire PID controller and provides the required high-frequency attenuation. In the Julia interface, a custom lower bound on the damping parameter must also be strictly positive when optimize_d = true.
The following configuration constrains integrated noise sensitivity for the active suspension model:
analysis ActiveSuspensionPIDH2Analysis
  extends DyadControlSystems.PIDAutotuningAnalysis(
    measurement = "y",
    control_input = "u",
    duration = 10.0,
    Ts = 0.01,
    Ms = 1.2,
    Mt = 1.2,
    Mks2 = 1e5,
    exact_h2 = true,
    filter_order = 2,
    Tf_lb = 1e-4
  )
  model = ActiveSuspensionForAutotuning()
end
The default Mks leaves the peak noise gain unconstrained in this example. Set a finite Mks to impose both bounds. The Julia interface uses the same Mks2 and Boolean exact_h2 options in AutoTuningProblem.
For discrete-time tuning (discrete_time = true), use exact_h2 = false. The frequency approximation uses
The factor
Advanced Options
Reference vs. Disturbance Step: By default, the disturbance step response is optimized. To optimize reference tracking, set
step_input = "reference_input".Controller Type: By setting parameter bounds, you can restrict the controller to P, PI, PD, or PID.
Filter Damping: With
filter_order = 2andoptimize_d = true, the damping ratio of the filter is also optimized.Penalizing Control Action: You can augment the model to penalize control effort or noise amplification.
Artifacts
A PIDAutotuningAnalysis returns the following artifacts:
Standard Plots
:SensitivityFunctions: Bode plot of sensitivity (S) and complementary sensitivity (T) functions.:NoiseSensitivityAndController: Bode plot of noise sensitivity (KS) and controller (K).:OptimizedResponse: Step response of the optimized closed-loop system.:NyquistPlot: Nyquist plot of the loop transfer function.
Tables
OptimizedParameters: DataFrame of the optimized PID parameters. The parameters are available for the parallel controller structure as well as converted to the standard form
Files
ControllerParameters: Tuned controller parameters as TOML forapply.